


Abstract
In this paper, a relaxed variable metric primal-dual fixed-point algorithm is proposed for solving the convex optimization problem involving the sum of two convex functions where one is differentiable with the Lipschitz continuous gradient while the other is composed of a linear operator. Based on the preconditioned forward–backward splitting algorithm, the convergence of the proposed algorithm is proved. At the same time, we show that some existing algorithms are special cases of the proposed algorithm. Furthermore, the ergodic convergence and linear convergence rates of the proposed algorithm are established under relaxed parameters. Numerical experiments on the image deblurring problems demonstrate that the proposed algorithm outperforms some existing algorithms in terms of the number of iterations.
MSC:
65K05; 68Q25; 68U10
1. Introduction
In this paper, we focus on the following convex optimization problem:
where is convex differentiable and its gradient is Lipschitz-continuous for some , is a proper lower semi-continuous convex function, is a bounded linear operator, and H and G are real Hilbert spaces. This problem is widely used in signal and image processing [1,2], compressed sensing [3], and machine learning [4]. For instance, a classical model in image restoration and medical image reconstruction is:
where is a blurring operator, is the observed image, is the regularization parameter, and is the total variation, which can be represented by a composition of a convex function with a discrete gradient operator.
We say that is a saddle point of (4) if and only if is a solution of (1) and is a solution of (3), respectively. The optimal solution set of problem (4) is denoted by . In this paper, we always assume that is nonempty.
Many efficient algorithms have been proposed for solving problem (1) in the last decades. Most of them are based on the alternating direction method of multipliers (ADMM) [5,6,7] and the forward–backward splitting (FBS) algorithm [8]. In [9,10], the authors showed that ADMM is equivalent to the Douglas–Rachford splitting algorithm [8]. The proximal gradient algorithm (PGA, also known as FBS) [11] is an efficient algorithm to solve (1) if , and some accelerated versions of PGA had been studied [12,13,14]. The primal dual hybrid gradient algorithm [15,16] was proposed to solve (1) without the smoothness of f. Combining the FBS algorithm [11] with the fixed-point algorithm based on the proximity operator (FPO) [17], Argyriou et al. [18] proposed a FBS_FPO to solve (1). Note that the FBS_FPO algorithm needs to solve a subproblem. Thus, it involves inner and outer iterations. To avoid choosing the number of inner iterations, Chen et al. [19] first a proposed the primal-dual fixed-point algorithm based on the proximity operator (PDFPO) to solve (1). Compared with the FBS_FPO, PDFPO only performs one inner iteration and reduces to the generalized iterative soft-thresholding algorithm [20] when . The PDFPO provided desirable performances to solve MRI reconstruction and TV-L1 wavelet inpainting [21,22]. In contrast, Combettes et al. [23] proposed a variable metric forward–backward splitting (VMFBS) algorithm to solve the saddle-point problem (4). By choosing a special variable metric, the PDFPO could be recovered by the VMFBS algorithm. Moreover, the proximal alternating predictor-corrector (PAPC) algorithm [24] was proposed to solve the equivalent minimization problem of (1) and was proved to converge linearly [25]. To speed up the PDFPO, Chen et al. [26] proposed an adapted metric version of PDFPO, which is termed as PDFPO_AM. The key feature of the PDFPO_AM is that it uses a symmetric positive matrix to replace the stepsize of the PDFPO. In contrast, Wen et al. [27] generalized the stepsize in the PDFPO to the dynamic stepsize. Later, a larger stepsize of PDFPO was proved [28]. Recently, Zhu and Zhang [29] introduced an inertial PDFPO (IPDFPO).
In Table 1, we summarize some variants of PDFPO.
Table 1.
Listing of existing primal-dual fixed point type algorithms.
From Table 1, we note that the relaxation parameter of these algorithms belongs to . It is well known that the convergence speed of the iterative algorithm can be accelerated when the relaxation parameter is greater than 1. This allows us to accelerate the PDFPO_AM with larger relaxed parameters. We reformulate the PDFPO_AM as the FBS algorithm and propose a primal dual fixed-point algorithm based on the proximity operator with relaxed parameters and variable metrics (Rv_PDFPO). Based on the fixed point theory, we prove the convergence of the proposed algorithm. At the same time, we point out that PDFPO_AM [26], PDFPO_DS [27], and PDFPO [19] are particular cases of Rv_PDFPO. Further, the convergence rates are established under the larger relaxed parameters, including ergodic and linear convergence. To verify the effectiveness and superiority of Rv_PDFPO, we apply it for solving the image-restoration problem and compare it with other algorithms.
The rest of the paper is organized as follows. In Section 2, we recall some preliminaries and related work. In Section 3, we deduce the Rv_PDFPO from the preconditioned FBS algorithm and provide some convergence results. In Section 4, we show the numerical results of Rv_PDFPO on solving image deblurring problem. Finally, we provide the conclusions.
2. Preliminaries and Related Work
In this section, we first provide some notations and definitions. Then, we briefly review some existing algorithms for solving (1).
Throughout this paper, H denotes a real Hilbert space endowed with scalar product , and the associated norm is . Let () denote the set of the symmetric positive definite (semi-definite) operator in H. For , the U-weighted inner product is and the corresponding U-weighted norm is defined by . and are the real Hilbert space endowed with the scalar product. Let and , the -weighted norm in is for . We denote by the class of all proper, lower semi-continuous, convex functions from H to . Most of these definitions can be found in [8].
Let be a set-valued operator. The domain, the graph, the zeros, and the inverse of A are represented by , and , , and the resolvent of A is
The operator is monotone, if for all . The monotone operator A is maximally monotone if there is no monotone operator B such that . Further, A is - monotone if for , . An operator is -cocoercive, for some , if , .
Let be nonempty and let . The fixed point set of T is denoted by , i.e., . T is -averaged, for some , if
Let , the Fenchel conjugate of f is
and the subdifferential of f is the maximally monotone operator
Further, when f is differentiable.
Let and , the scale proximity operator of f with respect to the metric U is
The scale proximity operator is the standard proximity operator when .
Related Work
To solve (1), Argyriou et al. [18] considered the following forward–backward splitting algorithm:
where . By the definition of proximity operator, (6) is equivalent to
In (8), one needs to solve the subproblem of v to obtain the update of . More precisely, we obtain the following inner–outer iterative algorithm:
where , j denotes the inner iteration, and J represents the maximum number of inner iteration. Here, denotes the largest eigenvalue of L when L is a matrix.
Chen et al. [19] proposed the PDFPO as follows:
where , , and . Let , and with the help of the Moreau decomposition, we obtain from (10) that
Let , we have
3. Relaxed Variable Metric Primal-Dual Fixed-Point Algorithm Based on Proximity Operator
In this section, we propose Rv_PDFPO for solving the minimization problem (1). The Rv_PDFPO is
3.1. Convergence Analysis
First, let us introduce the product space and define the operators:
and
Notice that if and only if . Although A is maximally monotone and B is cocoercive in K, the forward–backward splitting algorithm could not be applicable since , does not have a closed-form solution. To overcome this difficulty, we consider a preconditioned forward–backward splitting algorithm as follows:
where , , and
After simple calculation, we recover (13) from (14). In order to analyze the theoretical convergence of Rv_PDFPO, we make the following assumptions:
- (A1):
- , ;
- (A2):
- , for ;
- (A3):
- ;
- (A4):
- .
Under the assumption (A1), we have . Denote by .
Lemma 1.
Suppose that (A1) holds. Then the following statements hold:
- (1)
- is -averaged under ;
- (2)
- is -averaged under .
Proof.
(1) Let ; we have
which means that is -cocoercive. Hence, is -averaged.
(2) Since , is maximally monotone and is -averaged. Hence, is -averaged. □
Now, we are ready to present the main convergence theorem of Rv_PDFPO (13).
Theorem 1.
Suppose that (A1)–(A4) hold. Let be generated by (13). Then, we have the following:
- (1)
- For any , is monotonically decreasing and exists;
- (2)
- ;
- (3)
- converges weakly to a point in Ω.
Proof.
(1) Let . Notice that , . Then, we obtain
which implies that is decreasing and exists.
(2) Summing (16) from to , we obtain
It follows from (17) that
(3) Let such that . It follows from Lemma 2.3 in [30] that there is such that . Define , we have
which implies that . The second inequality in (19) holds by Lemma 3.4 of [31]. It follows from the demiclosedness of T that . By Opial’s lemma, we conclude that . This completes the proof. □
3.2. Connections to Existing Algorithms
In this subsection, we present a series of special cases of the proposed algorithm and point out connections to other existing algorithms.
3.3. Convergence Rates
In this subsection, we discuss convergence rates of (13).
3.3.1. Ergodic Convergence Rate
First, we establish the ergodic convergence rate.
Lemma 2.
Suppose that (A1) holds. Let be generated by (13). Then, for any , it holds that
Proof.
It follows from the property of proximity operator that
By the differentiability of f, we have
Theorem 2.
3.3.2. Linear Convergence Rate
Next, we establish a linear convergence rate of (13) with and . Therefore, . For convenience, we give an equivalent formulation of T as follows:
In addition, we make some additional assumptions. More precisely,
- (A5):
- is strongly monotone under , i.e.,
- (A6):
- is strongly monotone under the norm , i.e.,
- (A7):
- There is such that and for all .
Lemma 3.
Suppose that , , and hold. Then,
for , where .
Proof.
Let and . Then, we have
which concludes the proof with . □
Lemma 4.
Suppose that and hold. Then, for ,
where .
Proof.
Define . It follows from the fact that is firmly nonexpansive that
where . □
Theorem 3.
Suppose that holds. Suppose that hold or holds. Let be generated by (13). Let for . Then, converges linearly to the unique point , i.e.,
where , .
Proof.
Define . Note that and . It is clear that is -contractive for . Therefore, converges linearly to the unique fixed point of . □
4. Numerical Experiments
In this section, we apply the proposed Rv_PDFPO (13) to solve the deblurring problem (2) and compare it with those of the ADMM [5], PDS [32], PDFPO [19], and PDFPO_AM [26]. All of the experiments are performed under Windows 7 and MATLAB (R2014a) running on a laptop with an Intel Core 2 Quad CPU GHz with 4 GB of memory.
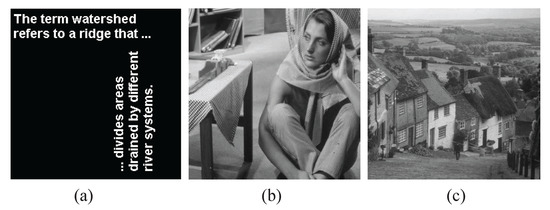
The test images are the standard “Text” image with a size of , and “Barbara” and “Goldhill” with a size , which are shown in Figure 1. We report numerical results on the image restoration for blurred images, corrupted by the Gaussian noise and the average kernel; a is the size of average kernel, and is the standard variance of the Gaussian noise. To evaluate the ability of the algorithm to remove different noises, we set four kinds of : (1) ; (2) ; (3) ; and (4) .
Figure 1.
These are the test images: (a) Text, (b) Barbara, and (c) Goldhill.
For the two common parameters and in PDS, and PDFPO, we set and . Similarly to the literature [26], we choose , where . In particular, can be easily computed by FFT with periodic boundary conditions. We tune the regularization parameter to achieve the maximum SNR, which is listed in Table 2.
Table 2.
The best selection of in the current noise level.
The relative error of the iterative sequences is defined as the stopping criteria:
where is a prescribed tolerance value. In the experiment, we choose . The quality of the restored images is evaluated by signal-to-noise (SNR), which is defined by
where x and denote the original and the recovered images. The obtained numerical results are listed in Table 3 and Table 4.
Table 3.
The performance of of the compared algorithms in terms of SNR (dB) and the number of iterations k for given tolerance values .
Table 4.
The performance of of the compared algorithms in terms of SNR (dB) and the number of iterations k for given tolerance values .
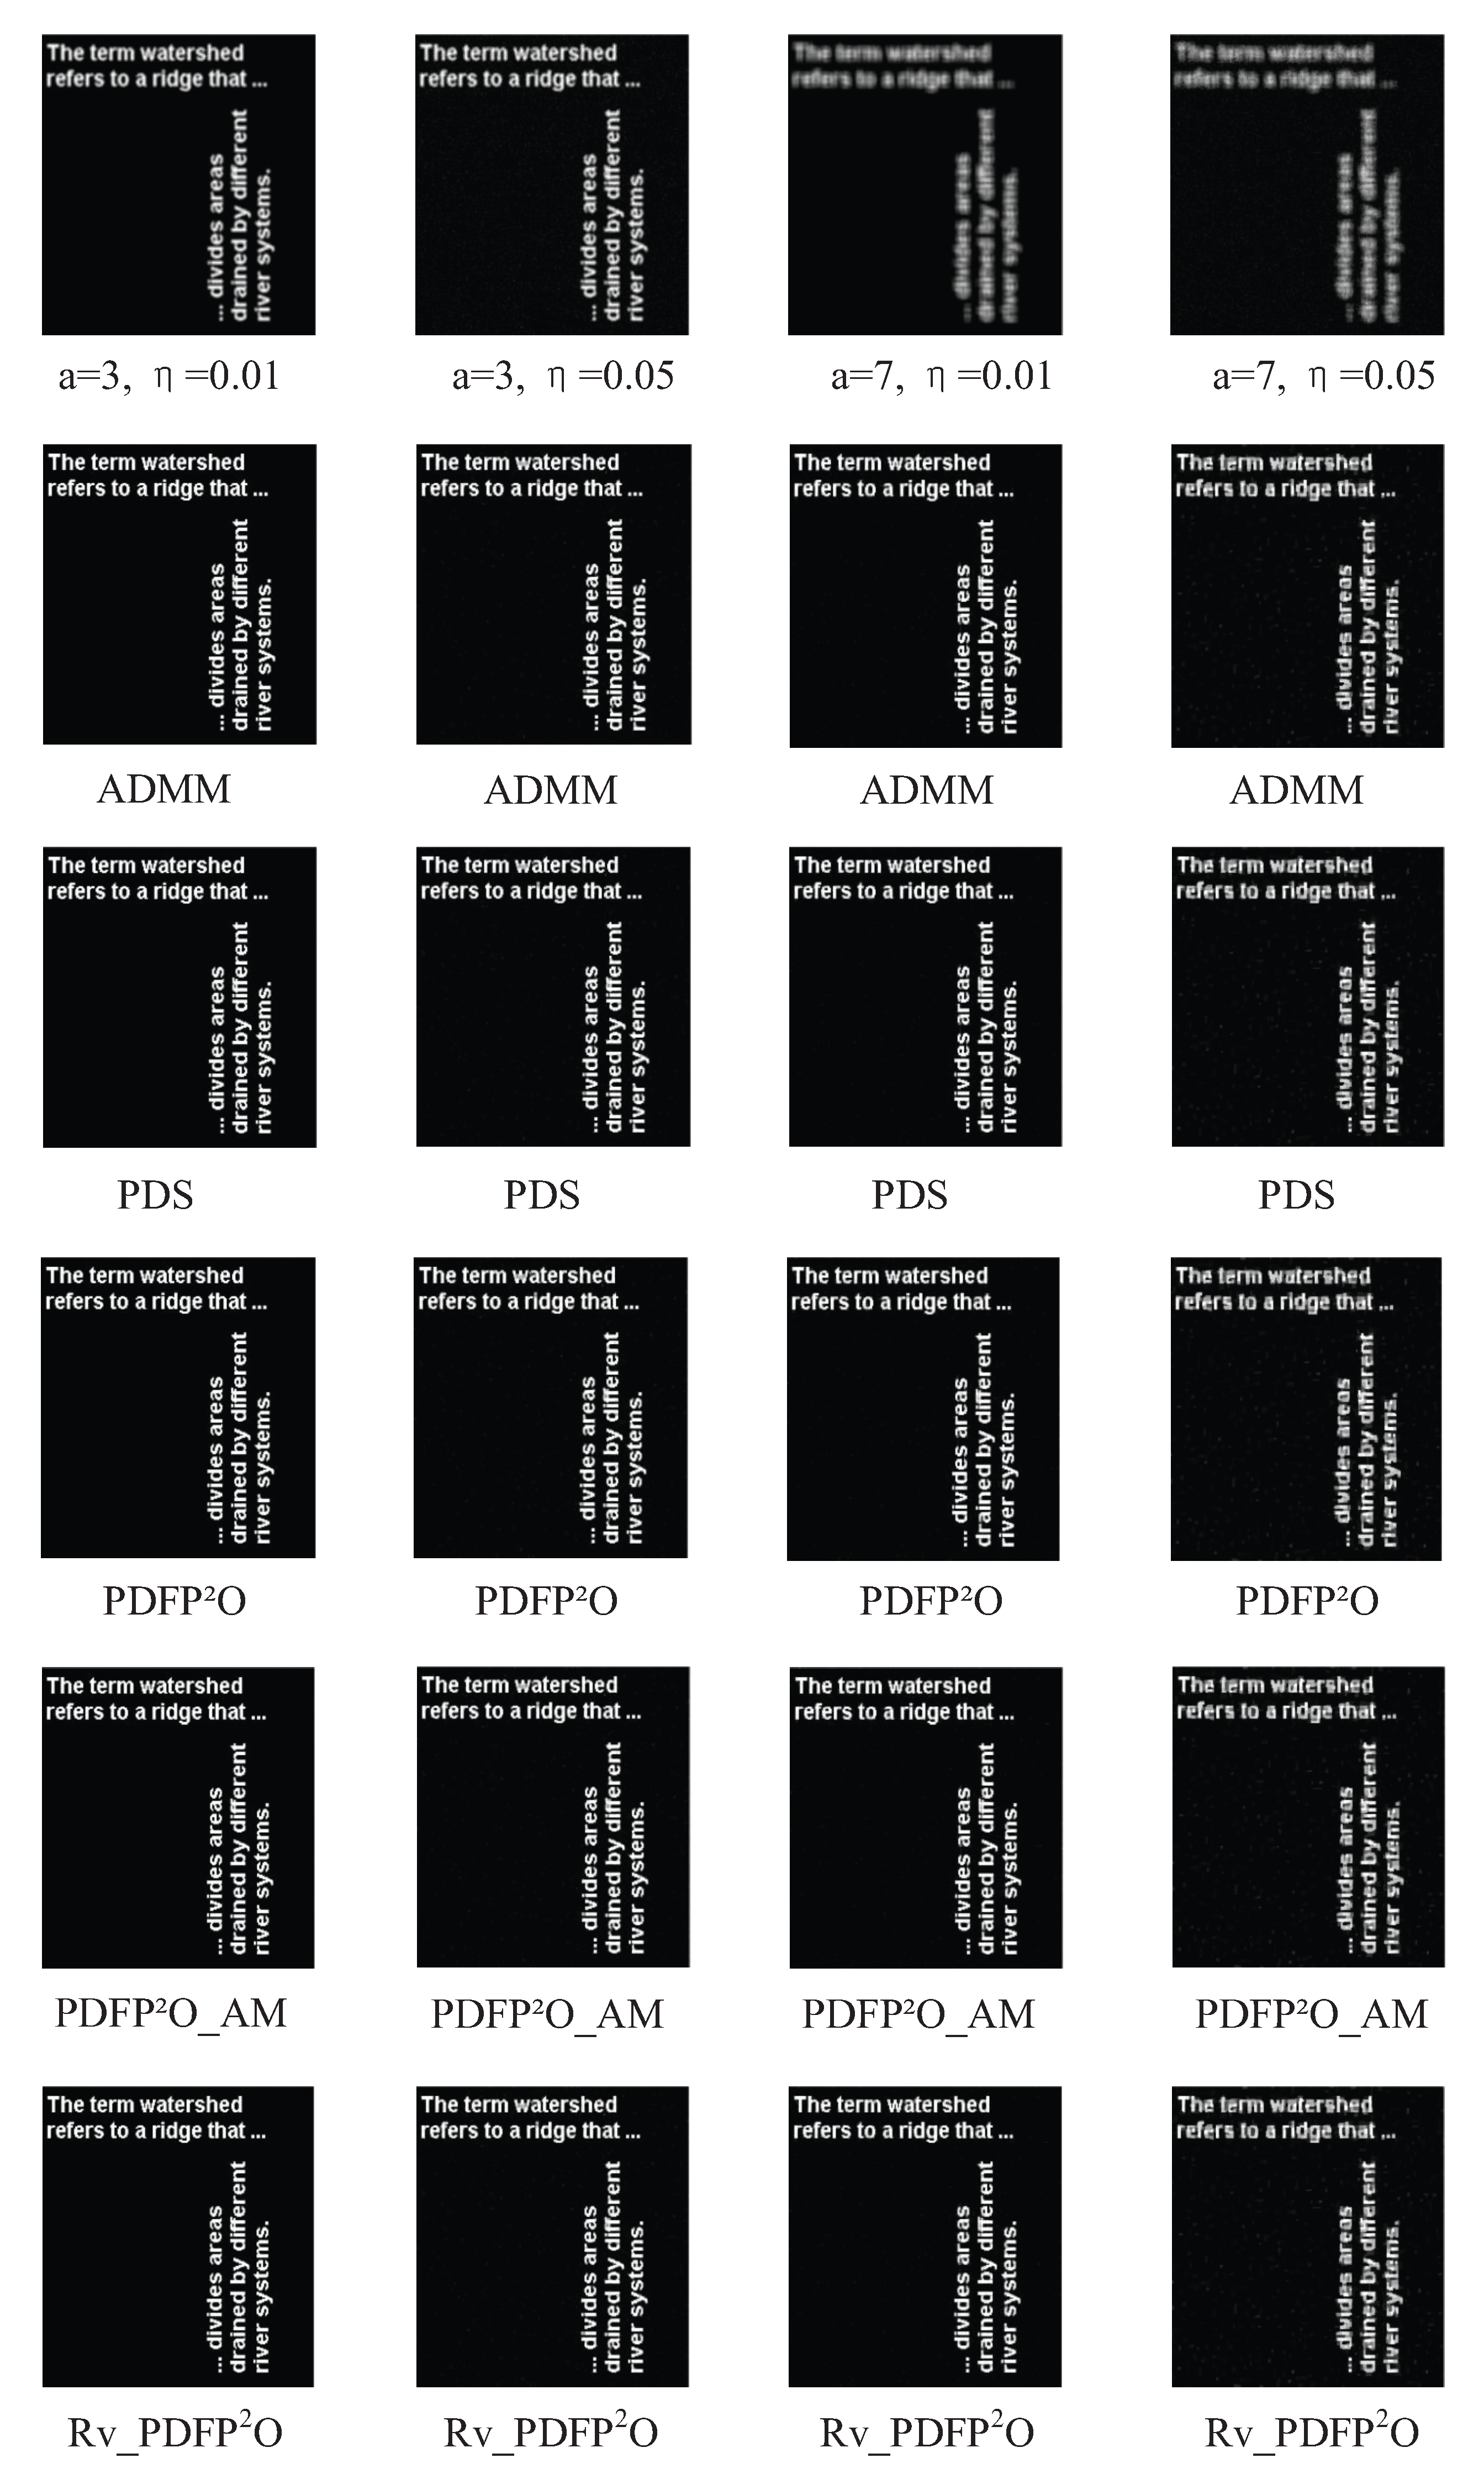
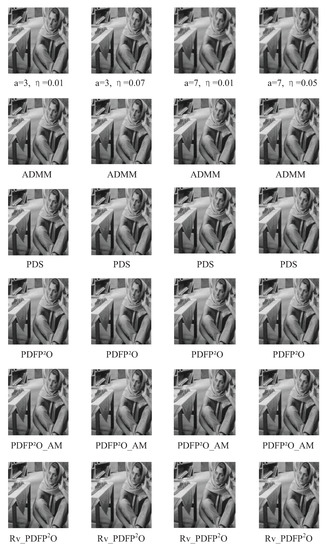
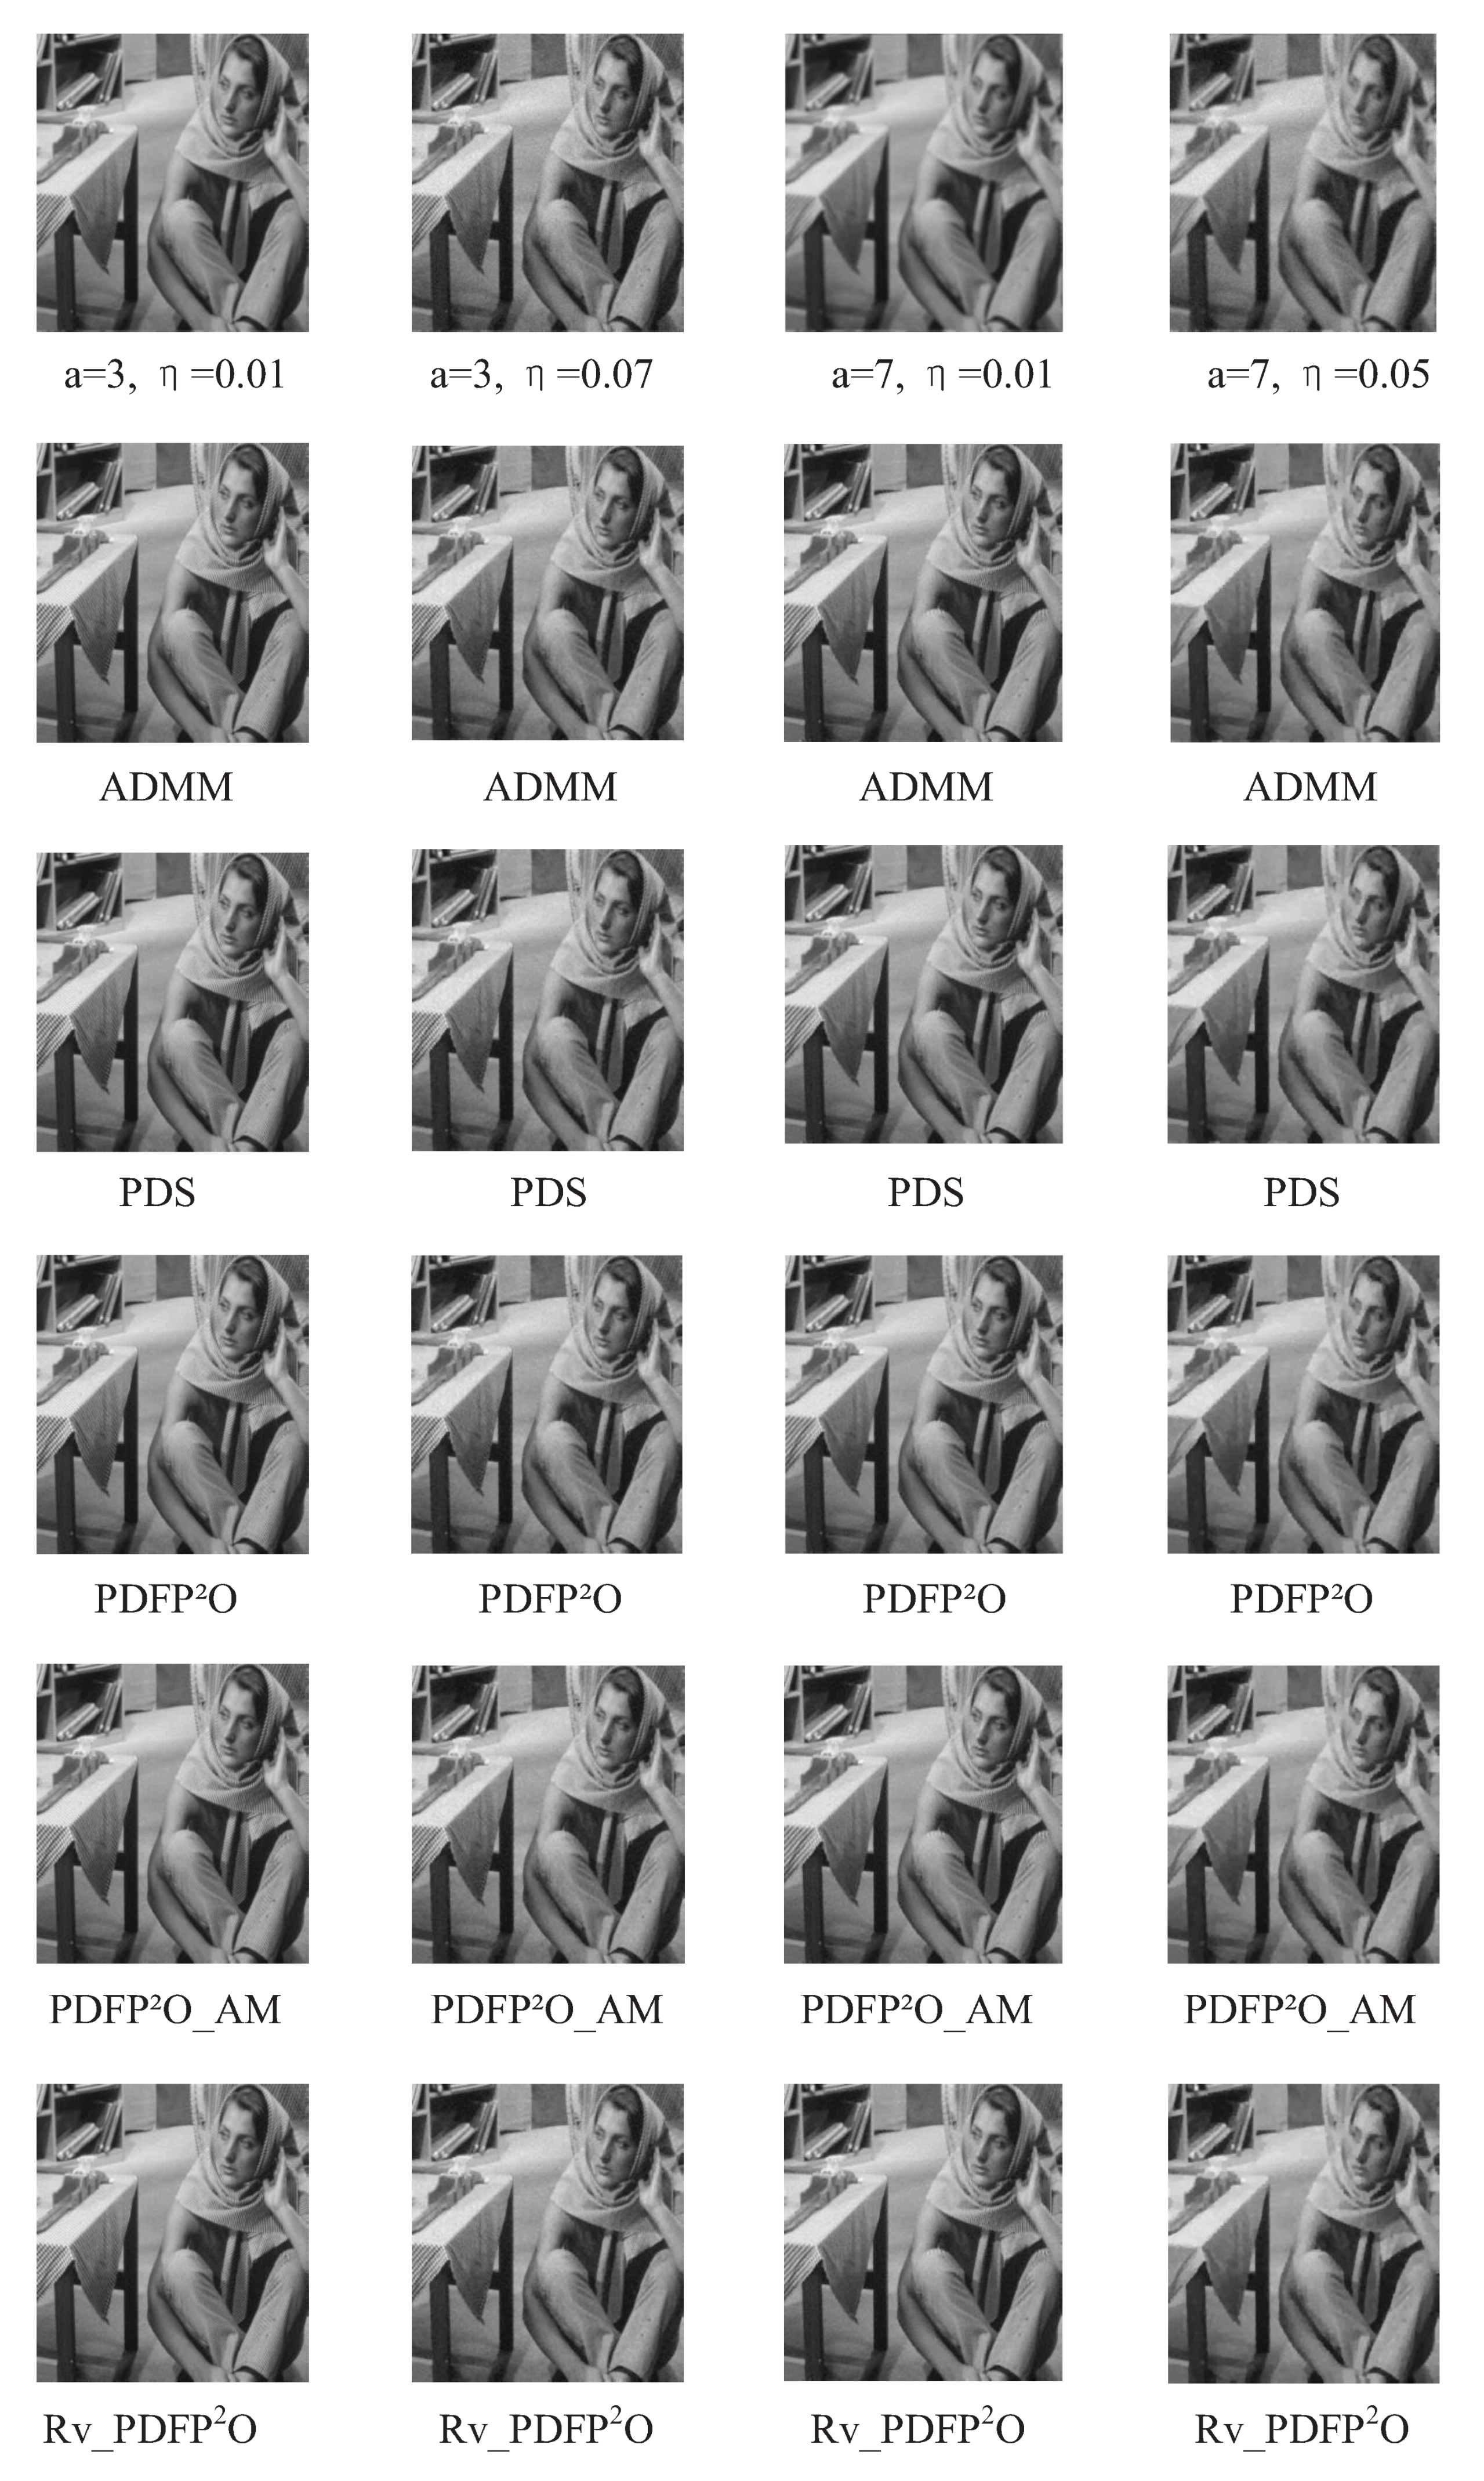
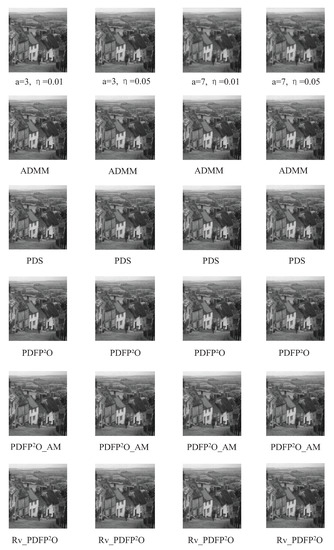
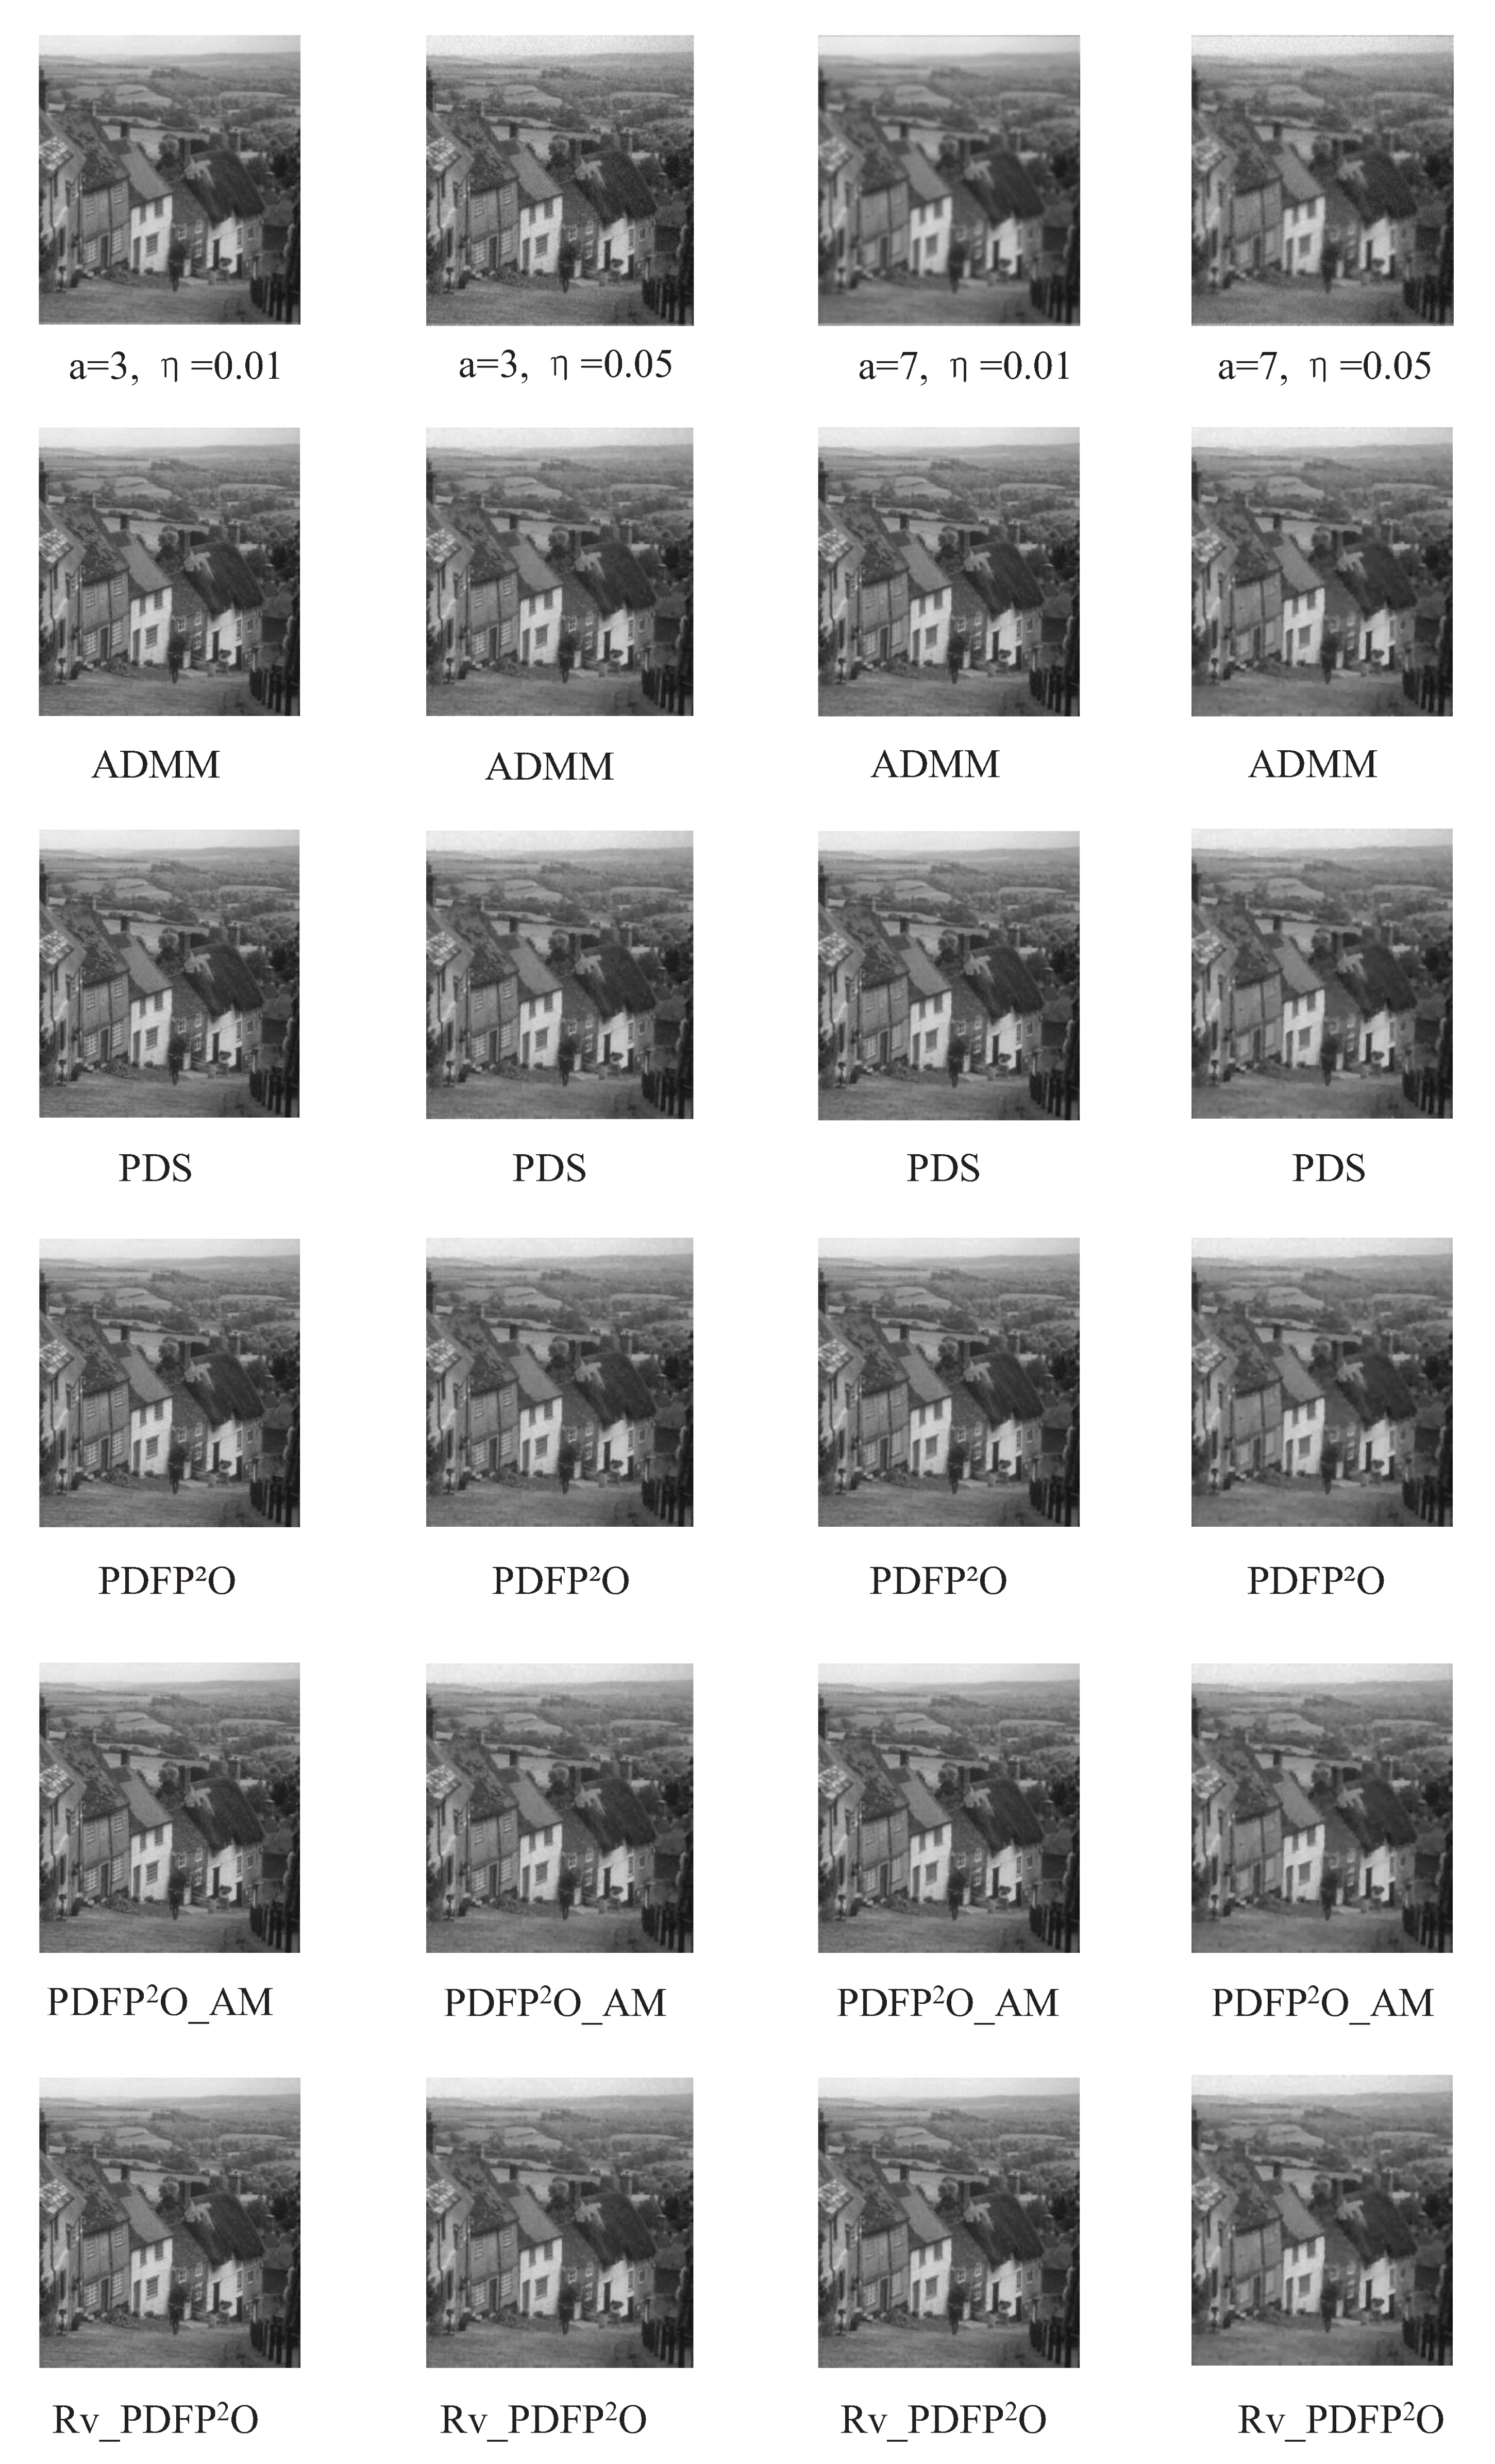
It can be seen from Table 3 and Table 4 that the proposed Rv_PDFPO converges faster than other algorithms in terms of the number of iterations. In addition, Figure 2, Figure 3 and Figure 4 show the recovered images with . Figure 2, Figure 3 and Figure 4 show that the visual qualities of these images obtained by the proposed algorithm are slightly better than the compared algorithms.
Figure 2.
These are the “Text” images: Row 1: the blurry and noisy images, Row 2: the images restored by ADMM, Row 3: the images restored by PDS, Row 4: the images restored by PDFPO, Row 5: the images restored by PDFPO_AM, and Row 6: the images restored by Rv_PDFPO.
Figure 3.
These are the “Goldhill” images: Row 1: the blurry and noisy images, Row 2: the images restored by ADMM, Row 3: the images restored by PDS, Row 4: the images restored by PDFPO, Row 5: the images restored by PDFPO_AM, and Row 6: the images restored by Rv_PDFPO.
Figure 4.
These are the “Goldhill” images: Row 1: the blurry and noisy images, Row 2: the images restored by ADMM, Row 3: the images restored by PDS, Row 4: the images restored by PDFPO, Row 5: the images restored by PDFPO_AM, and Row 6: the images restored by Rv_PDFPO.
5. Conclusions
In this article, we proposed a Rv_PDFPO to solve the convex optimization problem (1). The proposed algorithm combined the over-relaxed parameters and the variable metric. Under a proper preconditioned operator, we derived the Rv_PDFPO and established the convergence. By defining different stepsizes, we showed that the Rv_PDFPO recovers some existing algorithms, including PDFPO, PDFPO_AM, and PDFPO_DS, and we provide larger relaxed parameters for these algorithms. Furthermore, we studied the ergodic convergence rate in the partial primal-dual gap. Under some strong conditions on the objective functions and the stepsizes, we proved that the iterative sequences converge linearly. We applied the Rv_PDFPO to solve the TV image-restoration problem (2). The numerical results show that the Rv_PDFPO performs better than some existing algorithms. As we all know, the self-adaptive stepsize and the inertial variant could improve the algorithm. However, these two accelerated strategies are not introduced to the Rv_PDFPO algorithm. We would like to derive a self-adaptive Rv_PDFPO and an inertial Rv_PDFPO in the future.
Author Contributions
Conceptualization, W.H. and H.L.; methodology, W.H. and H.L.; software, Y.T. and M.W.; validation, W.H., Y.T. and H.L.; formal analysis, W.H. and Y.T.; and writing, W.H., Y.T., M.W. and H.L. All authors have read and agreed to the published version of the manuscript.
Funding
This work was funded by the National Science Foundation of China, grant numbers 12271117, 12061045, and 12001416, and the basic research joint-funding project of the university and Guangzhou city, grant number 202102010434.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Antonin, C.; Pock, T. An introduction to continuous optimization for imaging. Acta Numer. 2016, 25, 161–319. [Google Scholar]
- Rudin, L.I.; Osher, S.; Fatemi, E. Nonlinear total variation based noise removal algorithms. Phys. D Nonlinear Phenom. 1992, 60, 259–268. [Google Scholar] [CrossRef] [Scilit]
- Davenport, M.A.; Duarte, M.F.; Eldar, Y.C.; Kutyniok, G. Introduction to Compressed Sensing; Cambridge University Press: Cambridge, UK, 2012. [Google Scholar]
- Zou, H.; Hastie, T. Regularization and variable selection via the elastic net. J. R. Stat. Soc. Ser. B (Stat. Methodol.) 2005, 67, 301–320. [Google Scholar] [CrossRef] [Scilit]
- Boyd, S.; Parikh, N.; Chu, E.; Peleato, B.; Eckstein, J. Distributed optimization and statistical learning via the alternating direction method of multipliers. Found. Trends Mach. Learn. 2010, 3, 1–122. [Google Scholar] [CrossRef] [Scilit]
- Chan, R.H.; Tao, M.; Yuan, X.M. Constrained total variation deblurring models and fast algorithms based on alternating direction method of multipliers. SIAM J. Imaging Sci. 2011, 6, 680–697. [Google Scholar] [CrossRef] [Scilit]
- Han, D.R.; Yuan, X.M. A note on the alternating direction method of multipliers. J. Optimz. Theory Appl. 2012, 155, 227–238. [Google Scholar] [CrossRef] [Scilit]
- Bauschke, H.H.; Combettes, P.L. Concex Analysis and Monotone Operator Theory in Hilbert Spaces, 2nd ed.; Springer: Berlin/Heidelberg, Germany, 2017. [Google Scholar]
- Eckstein, J.; Bertsekas, D.P. On the Douglas-Rachford splitting method and the proximal point algorithm for maximal monotone operators. Math. Program. 1992, 55, 293–318. [Google Scholar] [CrossRef] [Scilit]
- Yan, M.; Yin, W.T. Self equivalence of the alternating direction method of multipliers. In Splitting Methods in Communication, Imaging, Science, and Engineering; Glowinski, R., Osher, S.J., Yin, W.T., Eds.; Springer: Cham, Switzerland, 2016; pp. 165–194. [Google Scholar]
- Combettes, P.L.; Wajs, V.R. Signal recovery by proximal forward–backward splitting. Multiscale Model. Simul. 2005, 4, 1168–1200. [Google Scholar] [CrossRef] [Scilit]
- Beck, A.; Teboulle, M. A fast iterative shrinkage-thresholding algorithm for linear inverse problems. SIAM J. Imaging Sci. 2009, 2, 183–202. [Google Scholar] [CrossRef] [Scilit]
- Beck, A.; Teboulle, M. Fast gradient-based algorithms for constrained total variation image denoising and deblurring problems. IEEE Trans. Image Process. 2009, 18, 2419–2434. [Google Scholar] [CrossRef] [Scilit]
- Iutzeler, F.; Malick, J. On the proximal gradient algorithm with alternated inertia. J. Optimz. Theory App. 2018, 176, 688–710. [Google Scholar] [CrossRef] [Scilit]
- Chambolle, A.; Pock, T. A first-order primal-dual algorithm for convex problems with applications to imaging. J. Math. Imaging Vis. 2011, 40, 120–145. [Google Scholar] [CrossRef] [Scilit]
- Komodakis, N.; Pesquet, J.-C. Playing with duality: An overview of recent primal-dual approaches for solving large-scale optimization problems. IEEE Signal Proc. Mag. 2015, 32, 31–54. [Google Scholar] [CrossRef] [Scilit]
- Micchelli, C.A.; Shen, L.X.; Xu, Y.S. Proximity algorithms for image models: Denoising. Inverse Probl. 2011, 27, 045009. [Google Scholar] [CrossRef] [Scilit]
- Argyriou, A.; Micchelli, C.A.; Pontil, M.; Shen, L.X.; Xu, Y.S. Efficient first order methods for linear composite regularizers. arXiv 2011, arXiv:1104.1436. [Google Scholar]
- Chen, P.J.; Huang, J.G.; Zhang, X.Q. A primal-dual fixed-point algorithm for convex separable minimization with applications to image restoration. Inverse Probl. 2013, 29, 025011. [Google Scholar] [CrossRef] [Scilit]
- Loris, I.; Verhoeven, C. On a generalization of the iterative soft-thresholding algorithm for the case of non-separable penalty. Inverse Probl. 2011, 27, 125007. [Google Scholar] [CrossRef] [Scilit]
- He, Z.; Zhu, Y.N.; Qiu, S.H.; Wang, T.; Zhang, C.C.; Sun, B.M.; Zhang, X.Q.; Feng, Y. Low-Rank and Framelet Based Sparsity Decomposition for Interventional MRI Reconstruction. IEEE Bio-Med. Eng. 2022, 69, 2294–2304. [Google Scholar] [CrossRef] [Scilit]
- Ren, Z.M.; Zhang, Q.F.; Yuan, Y.X. A Primal–Dual Fixed-Point Algorithm for TVL1 Wavelet Inpainting Based on Moreau Envelope. Mathematics 2022, 10, 2470. [Google Scholar] [CrossRef] [Scilit]
- Combettes, P.L.; Condat, L.; Pesquet, J.C.; Vu, B.C. A forward–backward View of Some Primal-dual Optimization Methods in Image Recovery. In Proceedings of the 2014 IEEE International Conference on Image Processing, ICIP 2014 Conference, Paris, France, 27–30 October 2014; pp. 4141–4145. [Google Scholar]
- Drori, Y.; Sabach, S.; Teboulle, M. A simple algorithm for a class of nonsmooth convex-concave saddle-point problems. Oper. Res. Lett. 2015, 43, 209–214. [Google Scholar] [CrossRef] [Scilit]
- Luke, D.R.; Shefi, R. A globally linearly convergent method for pointwise quadratically supportable convex-concave saddle point problems. J. Math. Anal. Appl. 2018, 457, 1568–1590. [Google Scholar] [CrossRef] [Scilit]
- Chen, D.Q.; Zhou, Y.; Song, L.J. fixed-point algorithm based on adapted metric method for convex minimization problem with application to image deblurring. Adv. Comput. Math. 2016, 42, 1287–1310. [Google Scholar] [CrossRef] [Scilit]
- Wen, M.; Tang, Y.C.; Cui, A.G.; Peng, J.G. Efficient primal-dual fixed-point algorithms with dynamic stepsize for composite convex optimization problems. Multidimens. Syst. Signal Process. 2019, 30, 1531–1544. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Yan, M. New convergence analysis of a primal-dual algorithm with large stepsizes. Adv. Comput. Math. 2019, 47, 1–20. [Google Scholar] [CrossRef] [Scilit]
- Zhu, Y.N.; Zhang, X.Q. Two Modified Schemes for the Primal Dual Fixed Point Method. CSIAM Trans. Appl. Math. 2021, 2, 108–130. [Google Scholar]
- Combettes, P.L.; Wajs, V.R. Variable metric quasi-fejer monotonicity. Nonlinear Anal-Theor. 2013, 78, 17–31. [Google Scholar] [CrossRef] [Scilit]
- Cui, F.Y.; Tang, Y.C.; Zhu, C.X. Convergence analysis of a variable metric forward–backward splitting algorithm with applications. J. Inequal. Appl. 2019, 2019, 1–27. [Google Scholar] [CrossRef] [Scilit]
- Condat, L. A primal-dual splitting method for convex optimization involving lipschitzian, proximable and linear composite terms. J. Optim. Theory Appl. 2013, 158, 460–479. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).